Delay a plan for later, and Yardstick in 17 languages
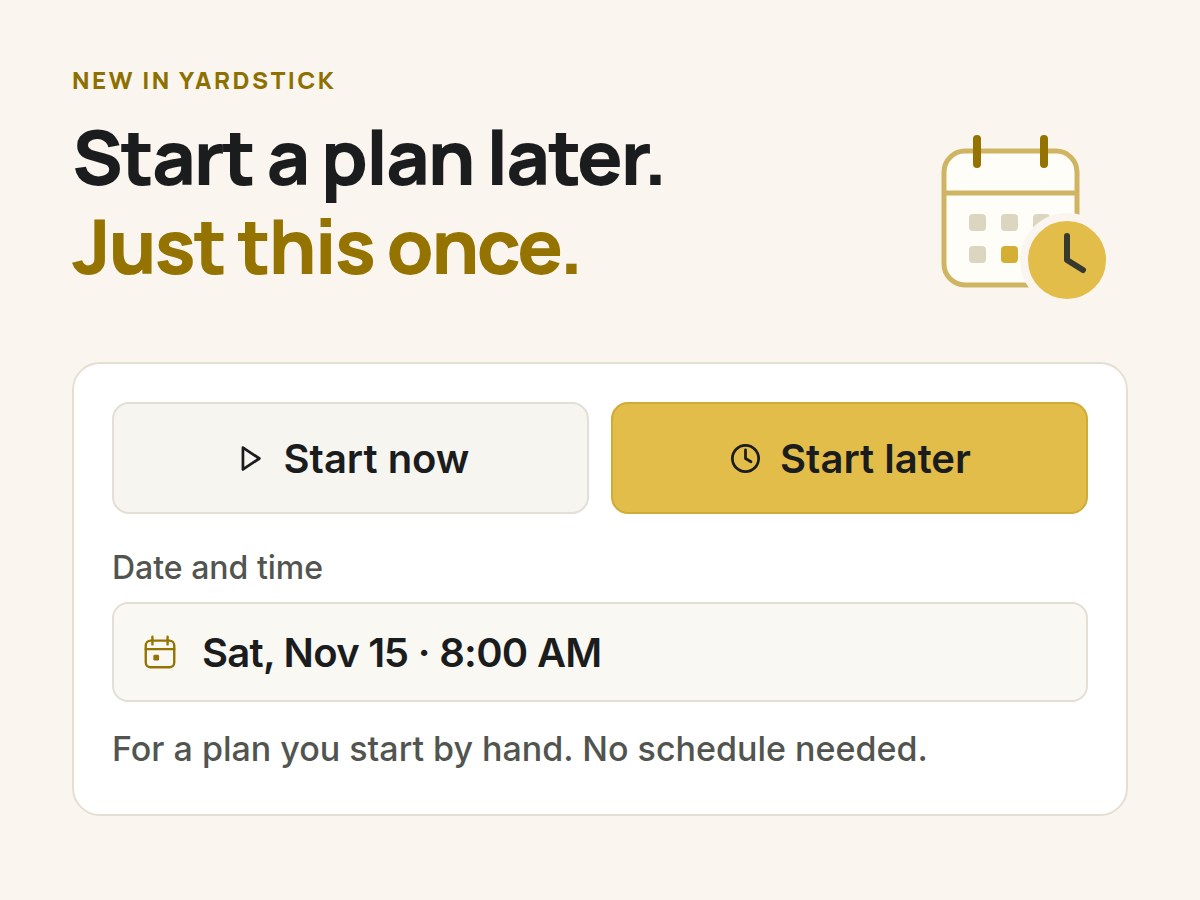
When you start a plan by hand, you can now choose Start later and pick a date and time up to a week ahead, on your yard's clock, and Yarbo runs it once. Press Start on the Plans page, in Quick run on the map or in the route preview, then choose Start later. Change or cancel it from the map, Plans or the Schedule. This complements the advanced scheduling system.
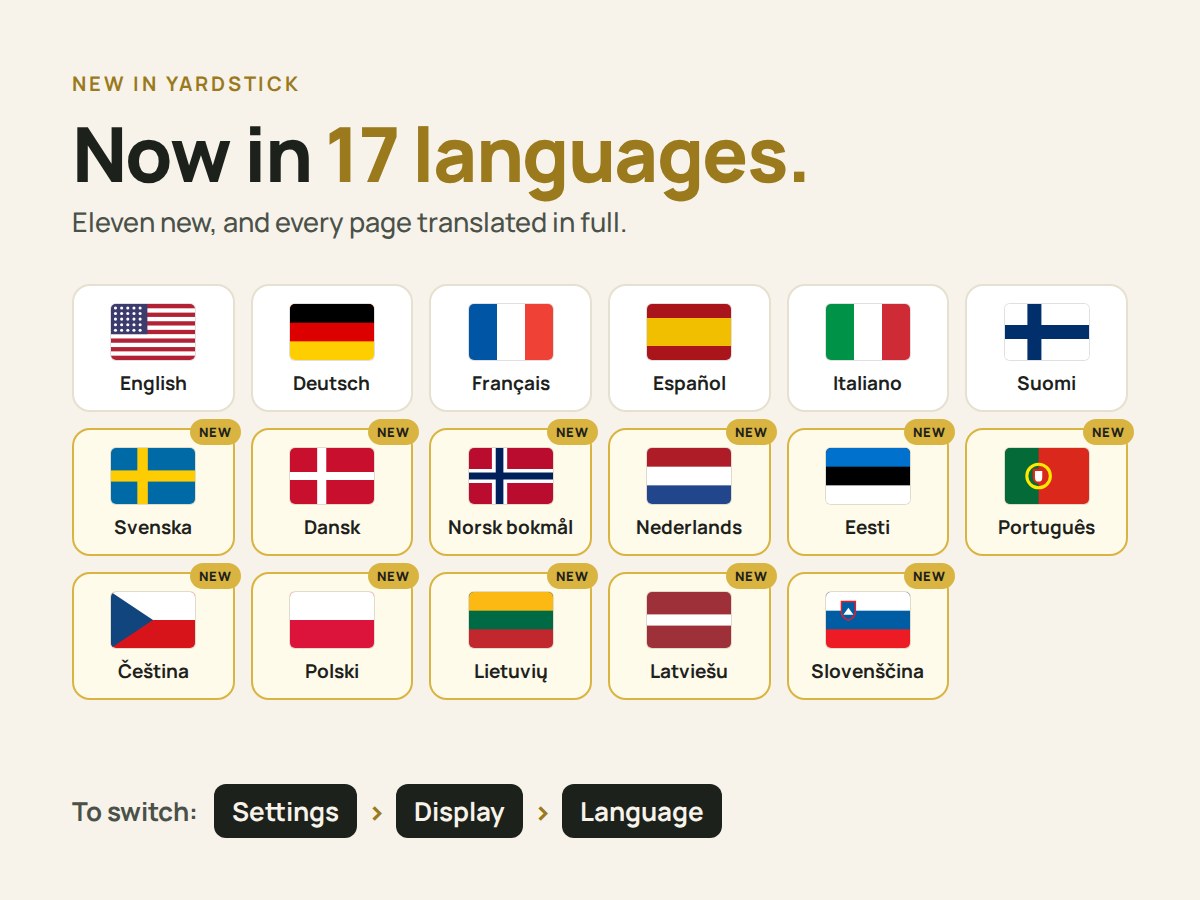
And Yardstick now speaks 17 languages: Swedish, Danish, Norwegian, Dutch, Estonian, Portuguese, Czech, Polish, Lithuanian, Latvian and Slovenian join English, German, French, Spanish, Italian and Finnish, on every page, alert and email. These updates also bring patrol lines in plans, rain that sends the mower home, obstacles broken out by kind, and a long list of fixes.
Where to find itStart, then Start later, on the Plans page or in Quick run; your language is in Settings, under Display, then Language
All 17 changes5 new · 5 improved · 7 fixed
- New
Delay a plan for later
Every Start now offers Start now or Start later: on the Plans page, in Quick run on the map (plans and programs), and in the route preview. Pick a date and time up to 7 days ahead on your yard's clock; a time inside quiet hours is refused, with when they end. The pending start shows on the map, the Plans page and the Schedule page, where you can change or cancel it, and each Yarbo can have one. At its time it starts the way a program does: quiet hours and weather rules hold it, and if Yarbo is busy, held or off its dock it waits up to 2 hours, then skips it and tells you why.
- New
Yardstick in 17 languages
Swedish, Danish, Norwegian, Dutch, Estonian, Portuguese, Czech, Polish, Lithuanian, Latvian and Slovenian join English, German, French, Spanish, Italian and Finnish, each translated in full and reviewed. Choose yours in Settings, under Display, then Language; alerts and emails follow it. The installer speaks eight of the new ones; Latvian, Lithuanian and Estonian installers stay in English, and the app itself speaks all of them. German, French, Spanish, Italian and Finnish were reviewed again for everything added since October, and What's new reads in every language.
- New
Patrol lines in plans
Your SAM patrol lines now have their own group on the Plans page, beside work areas, dead ends and sidewalks, so a plan can patrol them in the order you choose. The plan's row counts them, and the Yarbo app lists them only while the SAM is attached, as it always has.
- New
Rain sends the mower home too, if you want it
The rain watch, which sends the robot home when your own Tempest or Weather Underground station reports rain, now has a switch for the mower beside the one for the leaf blower. Turn on either or both under Settings, Weather. The mower's is off unless you turn it on, because the mower also has Yarbo's own Rain Detection; with it on, your station's reading sends the mower home as well, ends the rest of that day's program and tells you.
- New
A Help button in the menu
The last button in the menu along the top, Help, opens the Yardstick support site in a new tab: the guides, and where you open a help desk ticket.
- Improved
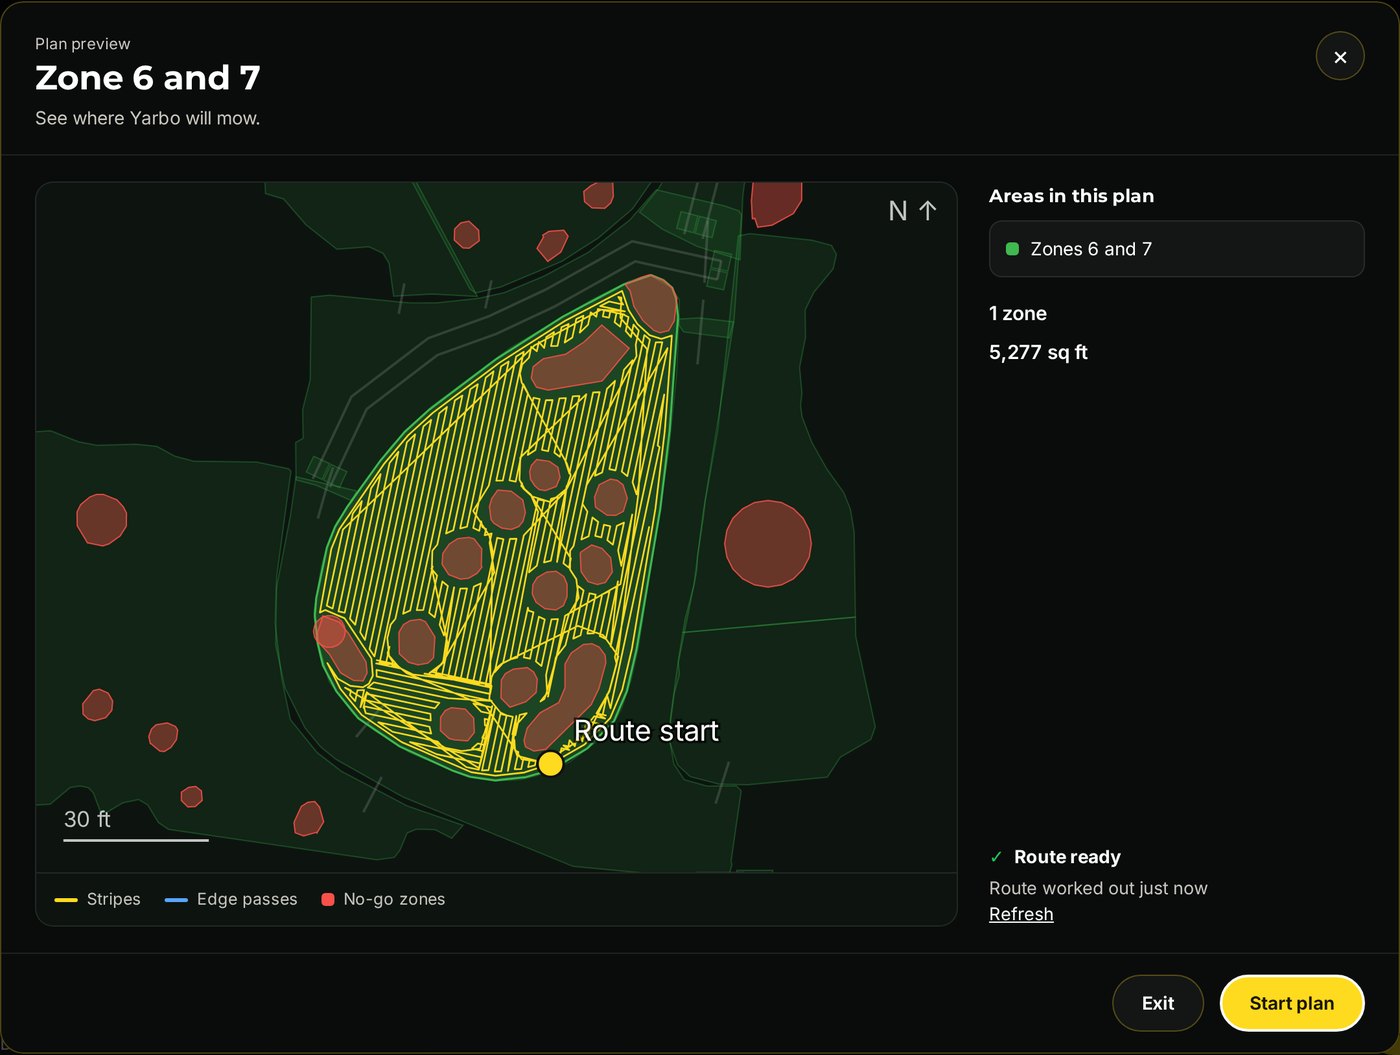
The route preview shows the no-go zones that apply
A no-go zone switched off in the Yarbo app is no longer drawn in the plan preview. Show all no-go zones, beside the legend, brings the switched-off ones back.
- Improved
Three red map colors for what the robot ran into
Under "Color the map by", Obstacle detections is now three colors, one for each of the robot's sensors. Ultrasonic detections shows where the ultrasonic sensors on the front picked something up on more than a quarter of the passes (it was half), and keeps everything recorded so far. Vision detections shows every place the cameras saw an obstacle, and Bumper hits every place the robot ran into something and its bumper was pressed, each shaded darker where it happened more often; these two fill in from now on. A color stays empty while that sensor is off on the robot or the attached module does not use it: camera detection does not work with the leaf blower.
- Improved
Color the map by is in alphabetical order
The list reads alphabetically in your language, and RTK quality is still where the map opens.
- Improved
Room for longer words, and Quick run folds
On a phone the Logbook counters stack one per row, the map editor's Fit button grows with its word, and the map's side buttons widen instead of breaking a word in two. The Quick run card on the map folds to its heading like the other cards, and remembers it.
- Improved
Pictures and sounds load once instead of every time
Your browser now keeps the wall's weather radar, the home-screen icon and your alarm sound, and asks Yardstick only whether they changed, so pages and the wall display load faster and use less of your network. The fonts are kept for good and are fetched again only when an update changes them. Live robot readings, settings and sign-in answers are still never kept.
- Fixed
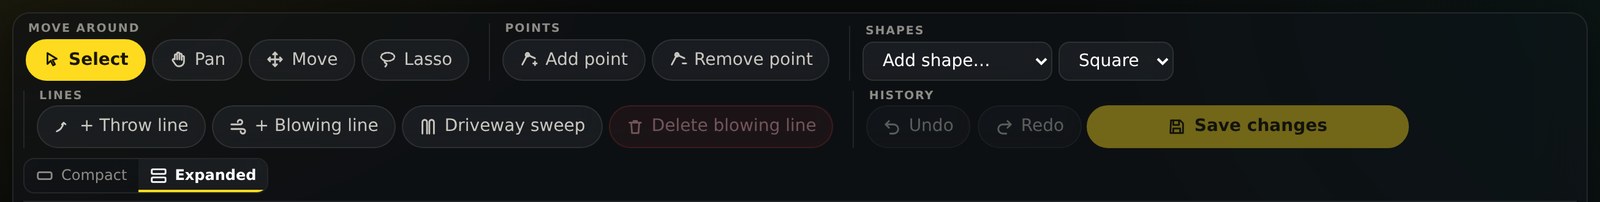
In limited circumstances, patrol lines drawn in Yardstick did not show in the Yarbo app
They worked on most maps. Adding a patrol line copied the first line on your map as its starting point, including what kind of line it was, so on a map whose first line was a pathway, every patrol line drawn in Yardstick was a kind the Yarbo app does not show. A new patrol line is now always the SAM's, and Add sidewalk makes a snow blower sidewalk. Patrol lines already on your robot that the Yarbo app cannot see are named when the map editor opens, with Make them patrol lines to fix them; nothing changes until you press it and then Save changes.
- Fixed
A restore no longer refuses a full robot resting on its dock
On Yarbo's newer firmware, and on the Y40P, a robot with a full battery stops reporting that it is charging, even on its dock, and a restore onto it was refused with "Dock the target core and finish its current job before restoring." Yardstick now also counts a robot as docked when it is still and its last position is within 5 m of a charger on its own map, as the alerts already do.
- Fixed
In an extremely limited circumstance, the live robot dot could sit away from the robot on new ground
It took a brand-new recording history, and we have seen it only once: the map's reference point moved each time the robot went further south or west than ever before, and for a few minutes the dot could sit many feet away from the robot. The reference point is now set once and kept. Existing installs keep the one they have, so nothing is rebuilt.
- Fixed
In certain circumstances, the Plans page showed a finished job as running
After a job ended with Yarbo still awake in the yard, the map called it blowing and the Plans page showed it as the current plan, while the map editor knew it was over. Both now go by whether a job is actually open.
- Fixed
In very limited circumstances, Work Preferences would not open
On a very few robots the Work Preferences page said "Could not read this Yarbo's Work Preferences" and Back up now stayed off, even though the robot answered with all its settings. Yardstick was expecting a label on the answer that those robots use differently. It now reads them, and saving a change works as before.
- Fixed
The map editor shows Yarbo's real map after a save it could not confirm
If Yarbo might have kept a change but did not confirm it, the editor now reads Yarbo's map again and shows it exactly as it is, and the edits still waiting to be sent are set aside and listed, so you can make them again on the map as it is now. Before, those older edits could be sent on top and undo a combine Yarbo had kept. Areas made by Split and Combine, and any area whose outline you change, now carry their own size, so Plans and the Yarbo app show the right figure.
- Fixed
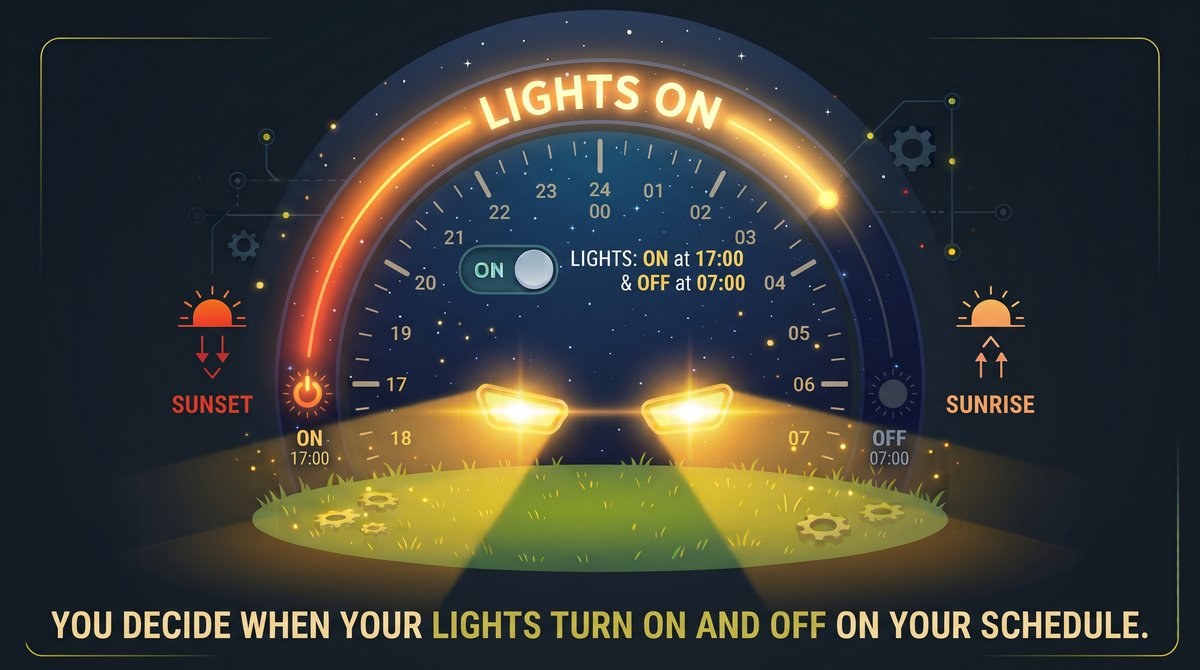
The path draws all the way home, and Lights after dark stays on while Yarbo heads home
When a job ended, Yardstick stopped keeping Yarbo's updates coming while it drove back to its dock, so on Yarbo's newest firmware the path home could go missing and Lights after dark could read Yarbo as stuck and turn the lights off on the way home. Yardstick now keeps the updates coming until Yarbo is on its dock. On the way home the lights now go by what Yarbo reports: they stay on while it is heading home or working its way around something in its path, and go off when it docks, is paused, reports a fault, or makes no progress for five minutes.